Robust Autonomy
for Certifiably Safe
Mobile Robots
Vision
Autonomous Mobile Robots (AMRs) could be mainstream.
They could deliver the mail. They could plow our fields.
They could extinguish forest fires.Building a robot could be as easy as building a video game: just focus on the content, take building blocks from a high-quality game engine. We want to make that happen.
They could deliver the mail. They could plow our fields.
They could extinguish forest fires.Building a robot could be as easy as building a video game: just focus on the content, take building blocks from a high-quality game engine. We want to make that happen.

The AI robot software stack
We know that the middle layer of the robotic stack is crucial.
It has to be of high quality. And it has to be designed and
certified for functional safety.
It has to be of high quality. And it has to be designed and
certified for functional safety.
Application Layer
Autonomy
Middle Layer
Middle Layer
AMR / AGV Platform
interfaces to orchestration & application logic
Robust Perception
Segmentation, Object Detection, Traversability
Reliable Localization
novel robust and real-time sensor fusion
Safe Guidance
Fail-safe trajectory generation
interfaces to low-level control & sensors
Localization
At any time, a robot needs to be able to enter a safe state. That means safely decelerating, avoiding obstacles and coming to stand-still at a safe spot.That's why the first component we tackled is localization: Without it, no controlled move can be taken. That's why currently nearly all mobile robots rely on a simple proximity based emergency brake system - far from true autonomy.
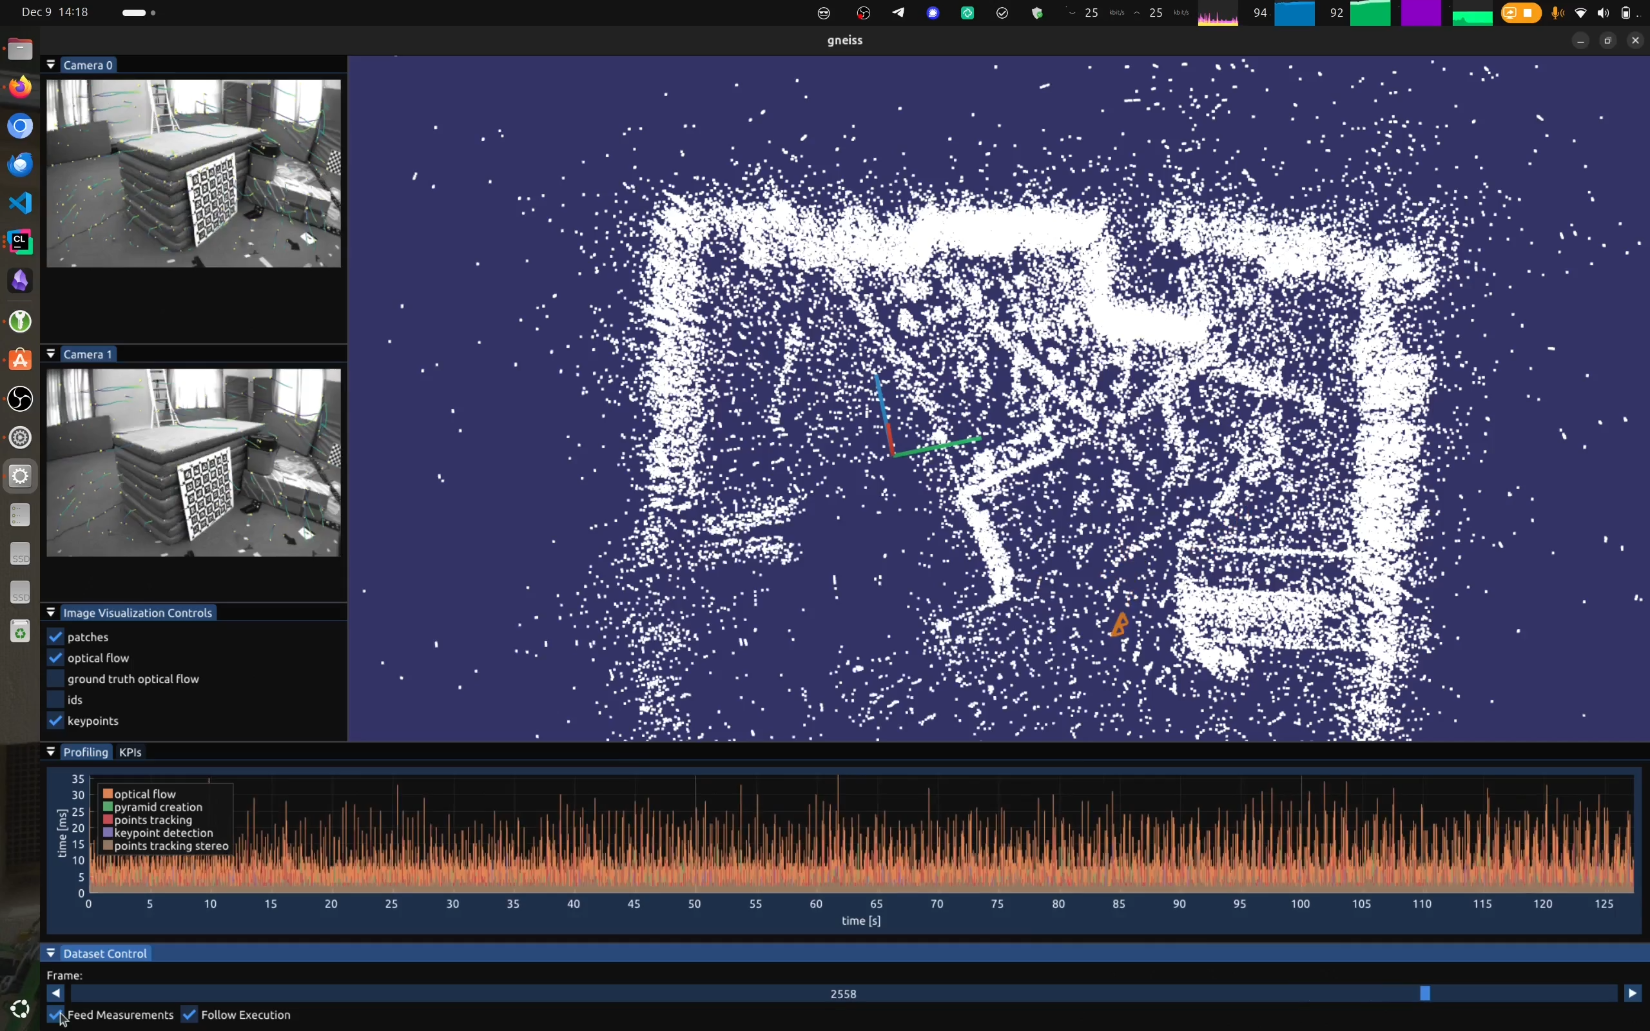
Gneiss for localization
To design smart autonomous behavior, relative localization
is crucial. Failure might be fatal. We solve it with our proprietary sensor-agnostic sensor fusion gneiss. It is deterministic and has limited error bounds, so it's certifiable.
is crucial. Failure might be fatal. We solve it with our proprietary sensor-agnostic sensor fusion gneiss. It is deterministic and has limited error bounds, so it's certifiable.

Visual Odometry & Sensor Fusion
global positioning
local positioning
(RTK) GNSS
Cellular (5G)
IMU
Cameras
LiDAR
Radar

robust position
Get started with gneiss
You want to try gneiss on your data or
explore benchmark results?
Team
We’re a team of experienced roboticists
and worked in the field of AMRs and
Computer Vision in research institutes
and industry for years.
You want to work with us on the remaining challenges or
discuss how geisterhand can help you to reach autonomy?
robo.innovate